Depth reprojection measures support beyond each solved camera.
Eight registered depth-warp chains tried step sizes from 0.5° up to a single 30° camera move, each one tracking how much of an output pixel still traces back to the solved source frame.
The corrected measurement is pleasingly blunt: one 30° move keeps … of the frame photograph-derived, while ten 3° steps keep …. Small steps open small holes, and each step then paints over the inventions of the one before it.
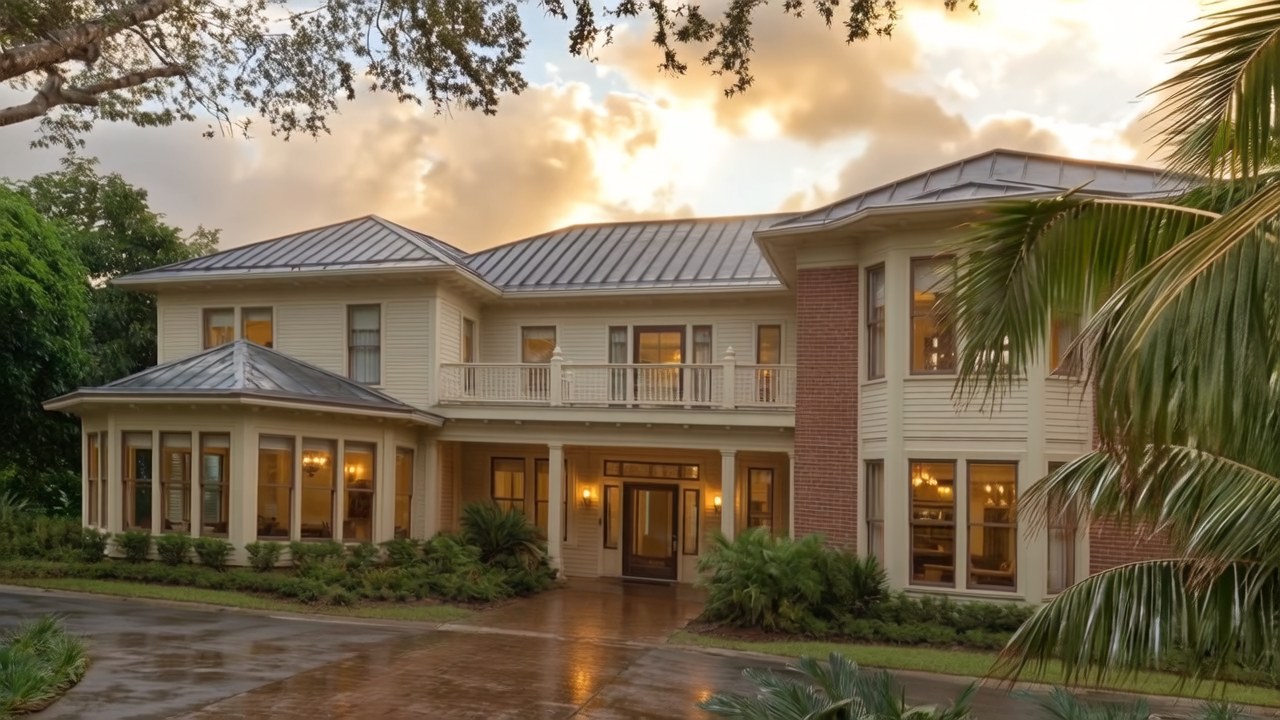
The solved frame
- invented
- 0.0%
- camera
- r4_0031, solved
Unmodified source frame from the fused solve.
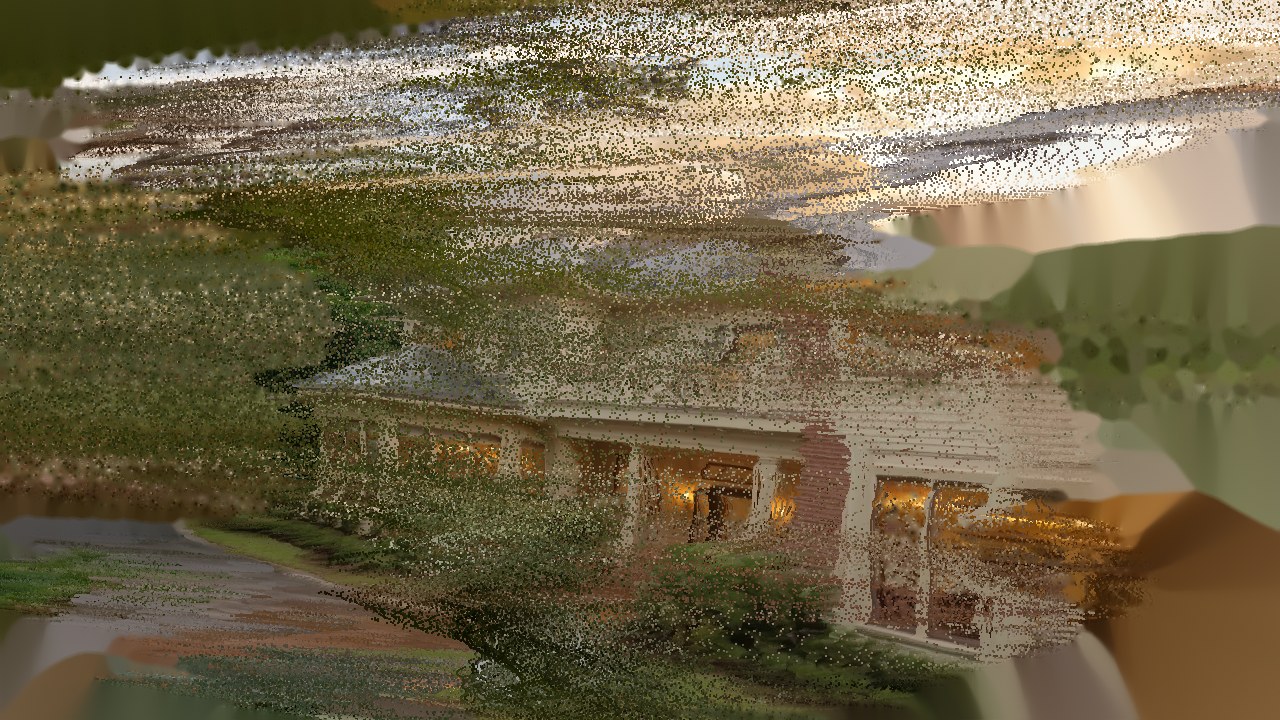
30° in a single warp
- invented
- 33.5%
- largest hole
- 16.2% in one piece
- steps
- 1
Two thirds of the frame remains source-derived.
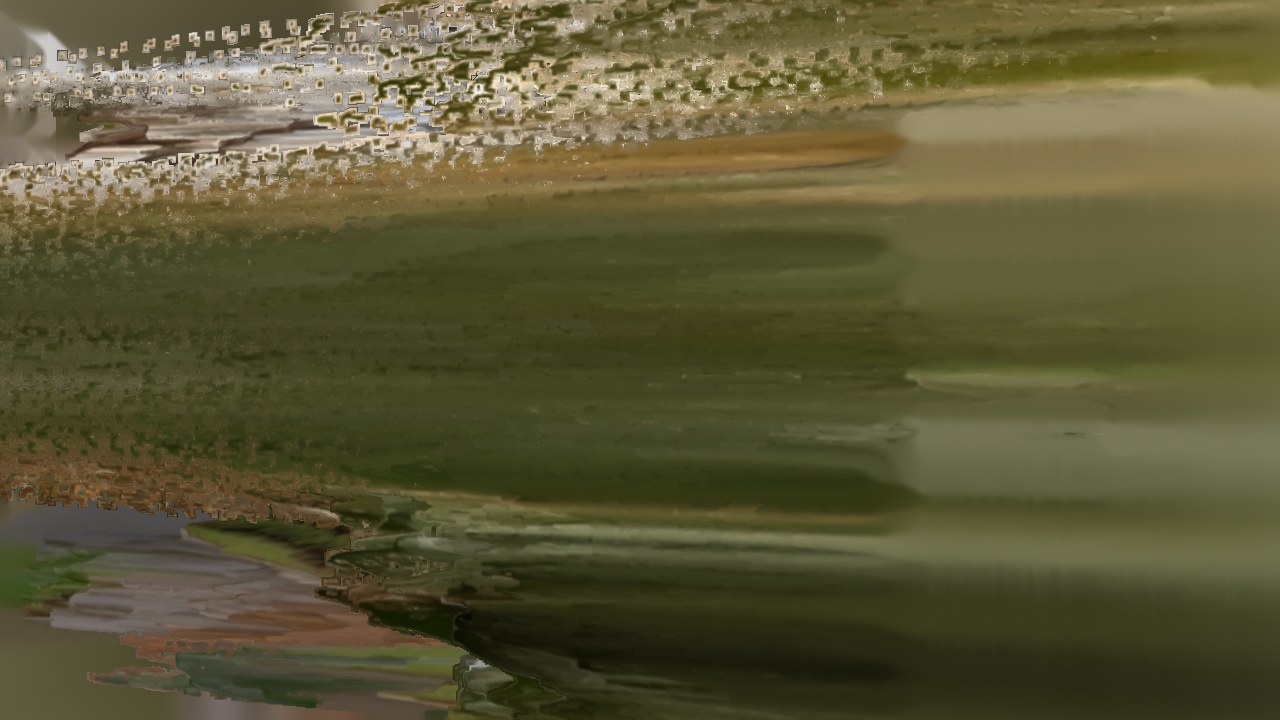
30° in ten 3° warps
- invented
- 73.0%
- largest hole
- 1.1%
- steps
- 10
Each step opens a small region, but the accumulated chain is 73% generated fill.
Re-rendering depth from the splat at every 3° step lifted retained source pixels from 27.0% to 33.4%, which settles where the loss lives: mostly in the compounding of invented fill, only partly in reused depth.

Available reach depends on the source frame and camera direction.
Direct reach was measured by invented-pixel fraction and largest contiguous hole. On r4_0031, at the far end of the arc, the two directions differ by … points: one requires … invented area and the other …. Other source frames reverse or eliminate that asymmetry, so reach is measured per warp. The lateral-dolly control required more generated fill than either orbit direction on every tested frame.

Superseded reach estimate: the solved frames cover … of azimuth, …. The 30°-limited measurement in this subsection used an incomplete visibility test. Section 08c applies the corrected facing rule and reports the current orbit-coverage estimate.
This study measures source-pixel provenance. Pixels outside the inpaint region remain unchanged, and no reconstruction was trained from these frames. All tests ran locally at $0.00. Data: dwi-chains.json and dwi-reach.json.
Legacy visibility measurement
The original visibility metric reported 66.5% source-derived pixels for one 30° warp and 27.0% for ten 3° warps. Files outside each inpaint region reproduced byte for byte. Section 08c preserves and corrects those values by rejecting back-facing surfaces.
A facing test stopped back-facing walls from lending pixels they could not have.
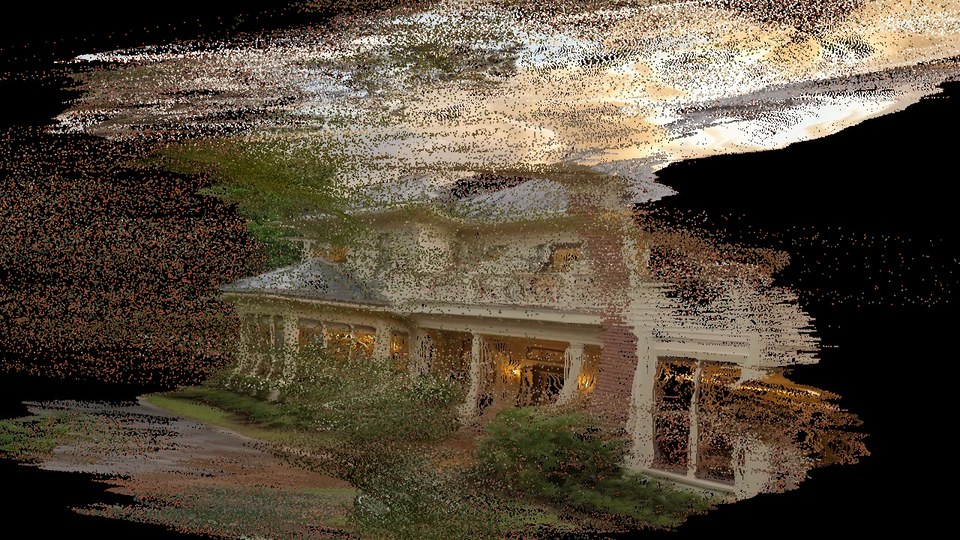
The original curve had 120° of orbit scoring … points cheaper than 90°. That impossible reversal exposed a measurement error. Back-facing facade pixels were passing straight through the unobserved building volume. The corrected rule accepts a source pixel only when its surface faces the destination camera, after sky masking, median-filtered depth and larger splat footprints were each ruled out as the cause.
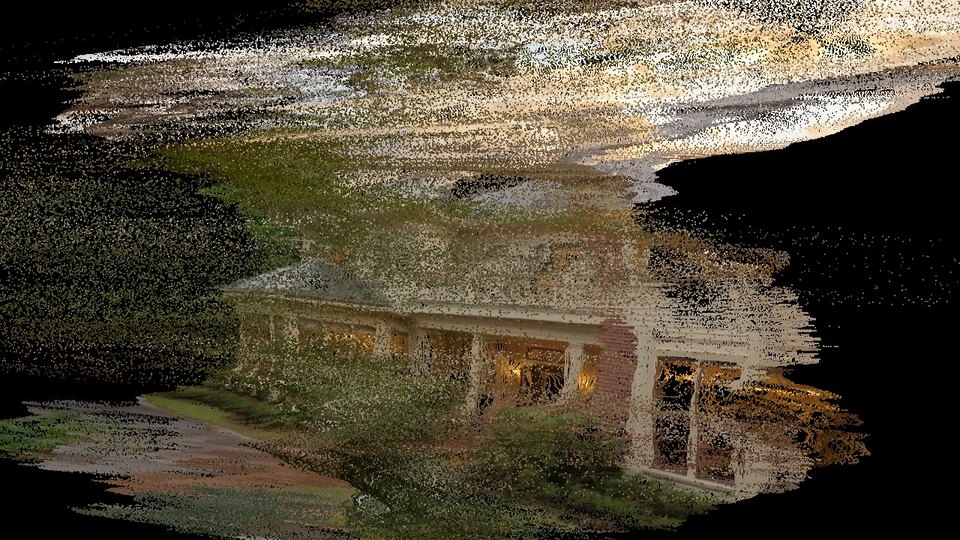
30°, no facing test
- invented
- …
- legacy interpretation
- 66.5% source-derived
The uncorrected metric accepts material whose surface faces away from the destination camera.
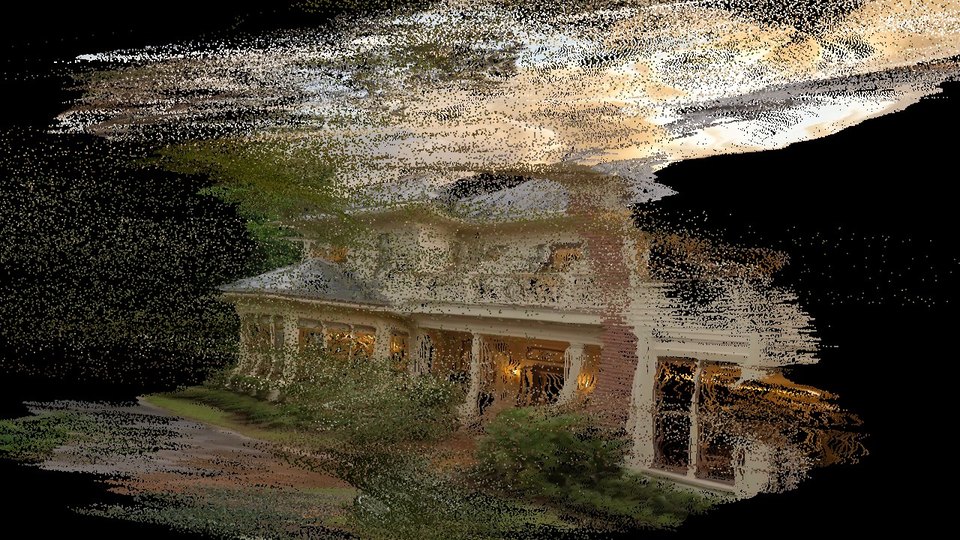
30°, facing test on
- invented
- …
- visual difference
- subtle at 30°
At 30°, the visual difference is small even though the corrected source-derived fraction is lower.
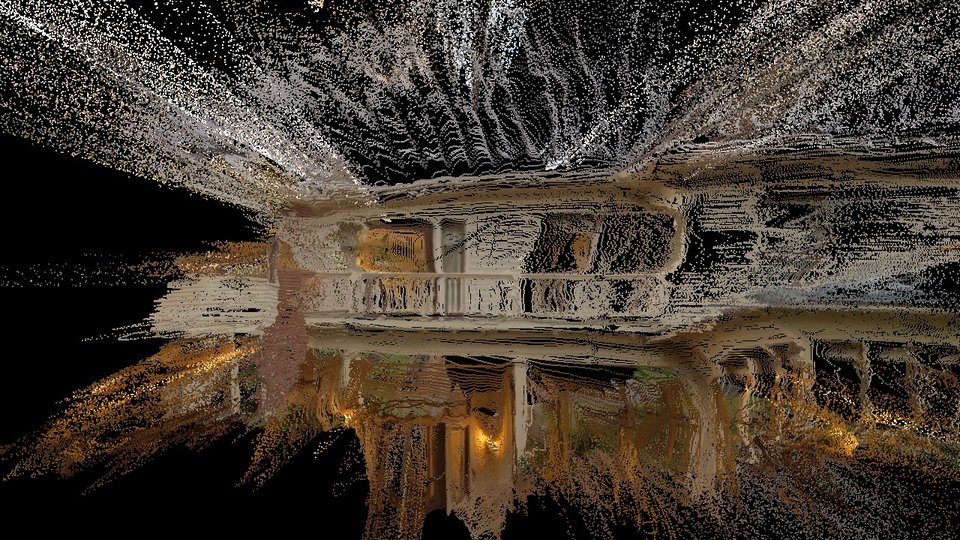
180°, no facing test
- invented
- …
- invalid content
- front facade visible from the rear
Without facing rejection, the 180° rear view receives a lower invented-pixel estimate than the 90° side view.
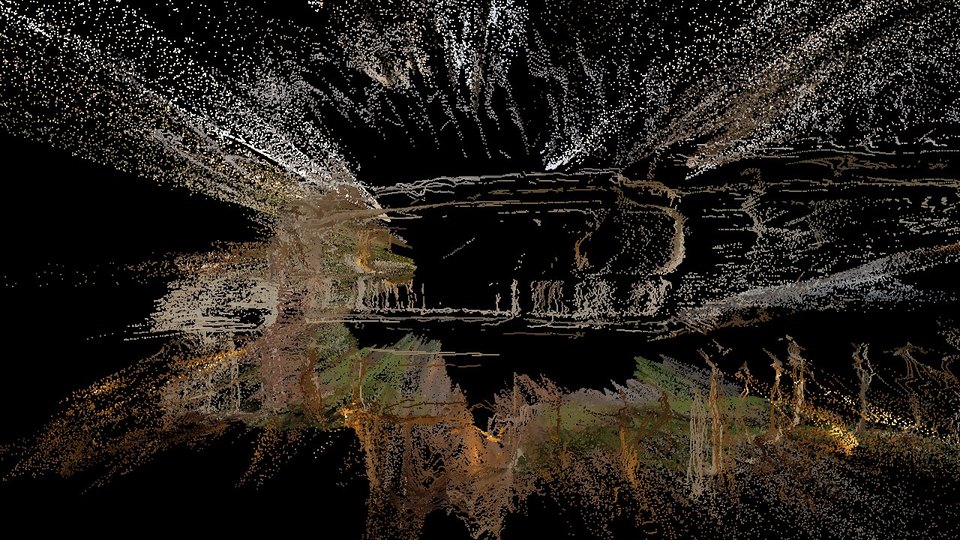
180°, facing test on
- invented
- …
- known source coverage
- almost none
A front-only capture provides almost no valid surface evidence for the rear elevation.

The corrected facing test lowers retained-source estimates for both decisive arms. The original single-jump value is …; the original ten-step value is …. The gap increases from … to … percentage points, strengthening the conclusion that repeated warping loses source evidence faster. Legacy plates retain their original labels for reproducibility.

Under the corrected facing test, 60% of the orbit has no reachable solved source frame. Depth warping genuinely extends the observed front arc, and the missing side and rear elevations need new evidence from somewhere else entirely. This local study cost $0.00. Data: dwi-far-reach.json.
Facing-test provenance
The corrected figures derive from the sealed r3 manifest. Payload hashes for the four comparison plates are recorded in dwi-facing-plates.json.